the I want to see the output response, but it gives me an error evaluating the system, and I was trying, it always happens when I put a system delayed with:
out1 = OutputResponse[Gc, 4.5, {t, 1, 100}];
You know I’m really disappointed with this, I was finding by myself at least 3 days, but I didn’t find nothing and documentation about outputresponse its not really helpful because outputresponse doesn’t have options, I’m new in this so I hope you can help me, I’m very grateful for your time reading this.
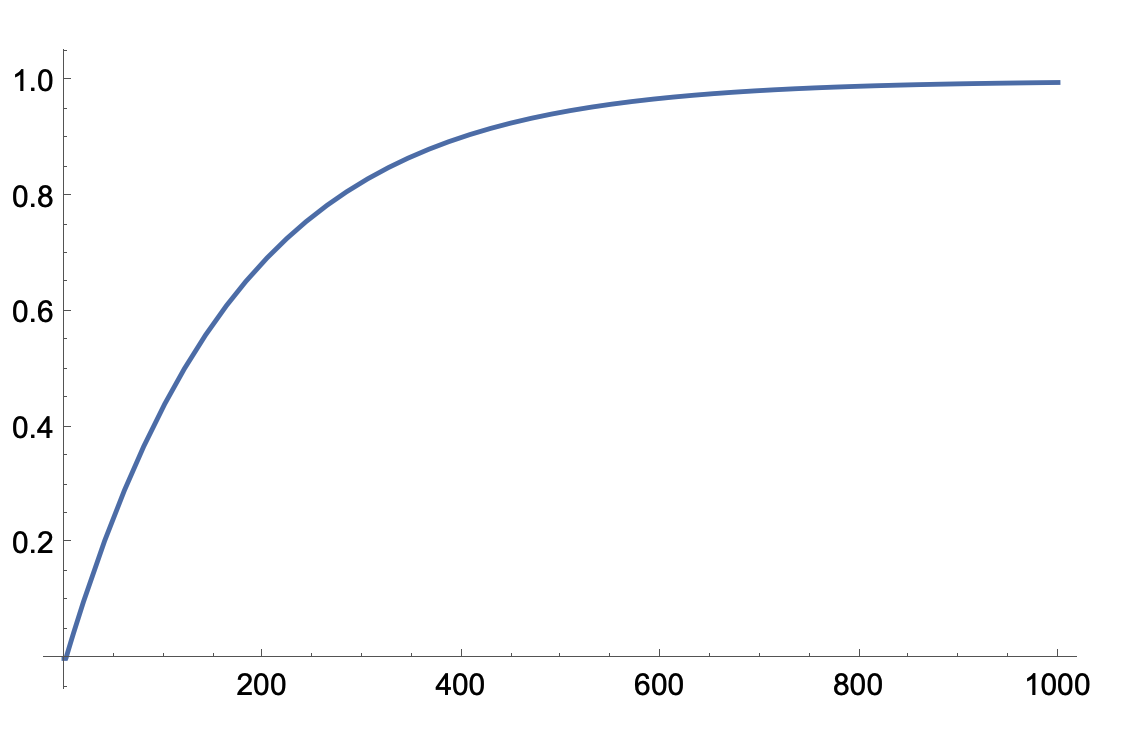
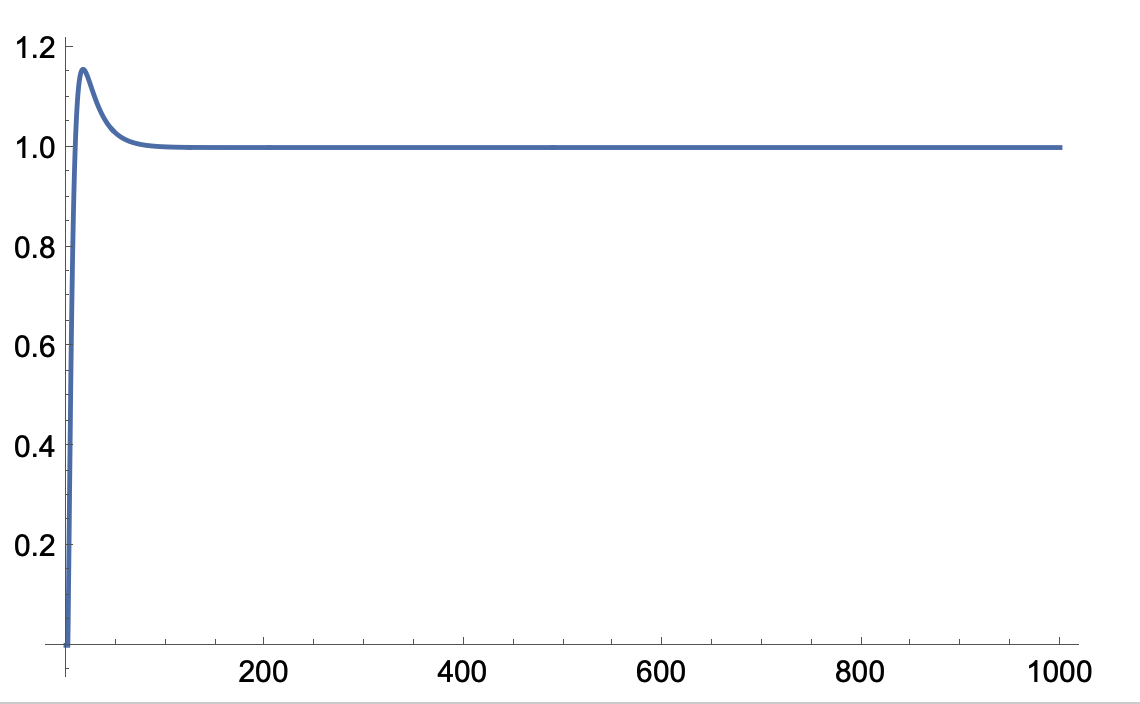
I do not know the inner workings for PIDTune, however, it appears to have difficulty with the derivative for a system with such a long time delay. If you use a PI controller with some options, you get a reasonable response. For example,
You can try different options to get different responses. If I were hand tuning it, I would tend to slow the system down more and get rid of the overshoot. I’m not sure why the PIDTune results are more oscillatory (especially with the default options). For details of why the addition of the derivative creates an unstable system and why the tune is not particularly good, I would see if @Suba Thomas has any insight that would help. It is generally difficult to use derivative action in a PID controller when the time delay is significant.