Hi,
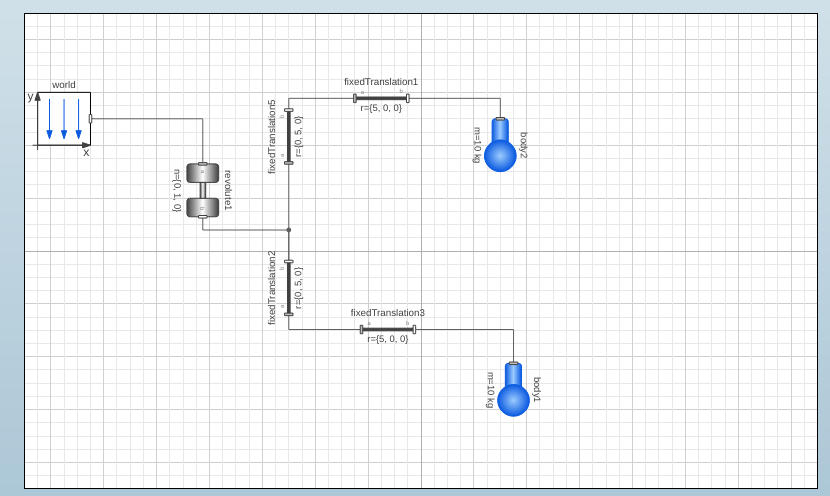
I have this model:

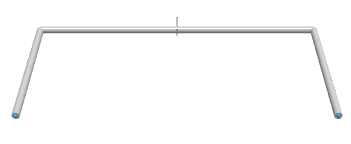
When I play it runs perfectly, here is a screenshot of the animation:

As expected, the model behaves like a pendulum connected by bars.
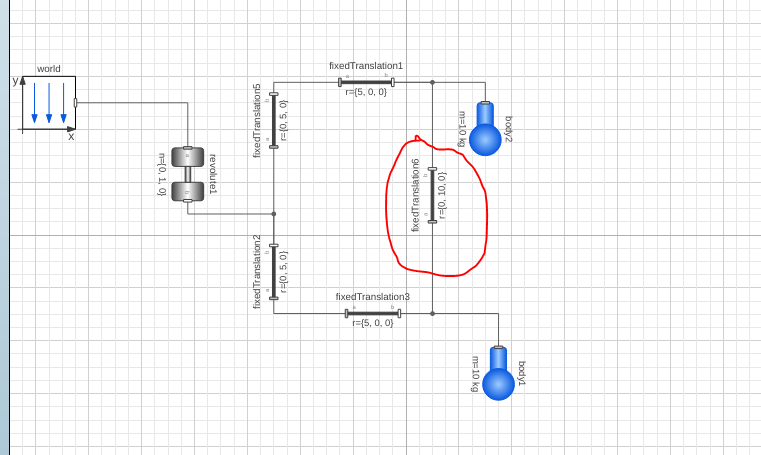
However, I would like to model with a fourth bar, something lke this:

The animation would something like this:

This results in a kinematic loop ( I guess it is the right term…). When I try
to simulate it, I get this error:
The following equations are redundant:
body2.frame_a.r_01 = body1.frame_a.r_01 + 10.0 * revolute1.R_rel.T[2,1]
body2.frame_a.r_02 = body1.frame_a.r_02 + 10.0 * revolute1.R_rel.T[2,2]
body2.frame_a.r_03 = body1.frame_a.r_03 + 10.0 * revolute1.R_rel.T[2,3] Corresponding variables with arbitrary value:
fixedTranslation6.frame_b.f1, fixedTranslation5.frame_b.t2,
fixedTranslation5.frame_a.t1 Message for
fixedTranslation6.frame_b.f1:
All Forces cannot be uniquely calculated. The reason could be that the mechanism contains a planar loop or that joints constrain
the same motion. For planar loops, use for one revolute joint per
loop the joint Joints.RevolutePlanarLoopConstraint instead of
Joints.Revolute.
I tried variations of this model, but I noticed that as far as I have the fourth bar (the one that closes the loop) I will have a problem to simulate. I think I understood the problem, I may sound dumb now, but what I have to do to model with the fourth bar? Is there a way to solve it?
The model follow attached to the post.
My SM short information:
Product version: 13.1.0.3 Client: Model Center Client version:
13.1.0.4 Client creation date: 2022-05-20T15:21:04.469569 Client build revisions: J:a111bde51, L:cc04976b1, S:dd80ee46c Client build
type: 64 bit Kernel version: 13.1.0.4 Kernel creation date:
2022-05-18T09:41:31.112079 Kernel build revisions: J:a111bde51,
L:cc04976b1, S:1d9b31919 Kernel root directory:
/usr/local/Wolfram/SystemModeler/13.1 Installation directory:
/usr/local/Wolfram/SystemModeler/13.1 Platform: Linux Mint 20.2
kinematic_test.mo (3.54 KB)