
ABSTRACT (original article): Numerical tools for computation of ℘-functions, also known as Kleinian, or multiply periodic, are proposed. In this connection, computation of periods of the both first and second kinds is reconsidered. An analytical approach to constructing the Reimann surface of a plane algebraic curves of low gonalities is used. The approach is based on explicit radical solutions to quadratic, cubic, and quartic equations, which serve for hyperelliptic, trigonal, and tetragonal curves, respectively. The proposed analytical construction of the Riemann surface gives a full control over computation of the Abel image of any point on a curve. Therefore, computation of ℘-functions on given divisors can be done directly. An alternative computation with the help of the Jacobi inversion problem is used for verification. Hyperelliptic and trigonal curves are considered in detail, and illustrated by examples. CITATION (original article): Julia Bernatska, Computation of ℘-functions on plane algebraic curves, arXiv:2407.05632. [2407.05632] Computation of $\wp$-functions on plane algebraic curves
See first part here: Uniformization of a genus 4 hyperelliptic curve with arbitrary complex branch points
Introduction
In this discussion Example 3 from arXiv:2407.05632 is considered in detail.
The present discussion can be considered as a continuation of discussion
Uniformization of a genus 4 hyperelliptic curve with arbitrary complex branch points
A genus g=3 trigonal curve \mathcal{C} in the canonical (3,4)-form, accurately defined below, serves as an example. A solution of the Jacobi inversion problem on this curve \mathcal{C} is obtained from the system
That is, given a point u = (u_1, u_2, u_5) \in \mathrm{Jac}(\mathcal{C}),
which corresponds to a class of non-special divisors, one can find a reduced divisor D, which represents the class, such that u=\mathcal{A}(D). This positive divisor D of degree g=3
serves as a common divisor of zeros of the two entire rational (polynomial in x and y) functions \mathcal{R}_6
and \mathcal{R}_7.
Multiply periodic \wp-functions, which arise in the definition of functions \mathcal{R}_6
and \mathcal{R}_7 are defined through the modular invariant entire function \sigma:
In fact, uniformization is given by six functions which serve as coefficients of \mathcal{R}_6
and \mathcal{R}_7. Namely:
These six functions uniquely define a class of divisors linearly equivalent to D such that u=\mathcal{A}(D).
Trigonal curve
We consider the simplest trigonal curve in the canonical form, known as (3,4)-curve, namely
At every x there exist three values of y, if the point is not a ramification point.
We solve the equation of the curve for y by the Cardano formula. Let
be the discriminant of the curve, and
Let q_1, q_2, q_3 denote three cubic roots of \upsilon:
where \upsilon^{1/3} is defined as follows
and \sqrt{\Delta} is defined as
Finally,
With the definition of \upsilon^{1/3} introduced above, every y_a has discontinuity over the contour \Upsilon = \{x \mid \arg \upsilon(x)=0\}, and the analytic continuation of y_a is
given by y_b, where a \mapsto b according to a cyclic permutation (123) or (132).
The definition of \sqrt{\Delta} introduces the contour \Gamma = \{x \mid \arg \Delta(x)=0\}, composed of segments \Gamma_i, each starts at e_i and goes to infinity. Here e_i is
the x-coordinate of a branch point B_i = (e_i,h_i) such that h_i = y_a (e_i) = y_b (e_i ).
Then y_a and
y_b have discontinuity over the contour \Gamma, and
y_b serves as the analytic
continuation of y_a on the other side
of \Gamma_i, and vice versa.
Curve in Example 3
More precisely,
The curve has eight finite branch points:
In the right column the corresponding pair ‘a\text{-}b’ is indicated, that is the pair of solutions y_a
and y_b which coincide at e_i.
On the figure below, the contour \Upsilon is marked in green, and the direction in which y_a, a=1,2,3, connect according to the cyclic permutation (123)
is indicated by green arrows. The contour \Gamma is marked in blue, and a pair ‘a\text{-}b’ in blue indicates which solutions y_a
and y_b connect along each segment of the contour.
Some segments \Gamma_i are intersected by
the contour \Upsilon. At the points of such an intersection the pair ‘a\text{-}b’ changes
according to the cyclic permutation of y_a, a=1,2,3, along \Upsilon.

Riemann surface
A trigonal curve has three sheets, which we denote Sheet A, Sheet B, and Sheet C.
Two sheets join at every branch points, and all three sheets join at infinity.
The corresponding Riemann surface is obtained by making g+1=4 cuts along which two sheets are connected. Cuts are made between pairs of points:
- from B_2 to B_3 on sheets with solutions y_1 and y_3,
- from B_4 to B_5 on sheets with solutions y_1 and y_2 in the vicinity of B_5 which change
consequently into the pair 1-3 and then 2-3 when approaching B4, - from B_6 to B_7 on sheets with solutions y_2 and y_3 in the vicinity of B_7 which change into the pair 1-2 when approaching B_6.
- from B_8 to infinity, and then to B_1.
Further computations require the knowledge how y_a, a=1,2,3, change on each sheet. For this purpose, we draw a continuous path \tilde{\gamma} on the x-plane from -\infty to \infty through all points e_i. The figure below shows this path, marked by orange. The path through all points e_i is displayed by dashed lines between e_2 and e_8. The path \tilde{\gamma} can be continuously deformed into a simpler path \gamma, displayed by solid lines.
The both paths are polygonal, and go below points e_i,
cuts are rounded counter-clockwise.

The path \widetilde{\gamma} marks sheets as follows
By a_{i,j} the value a of y_a on segment [e_i,e_j] is denoted on Sheet A,
then by b_{i,j} and c_{i,j} similar values are denoted on Sheet B, and Sheet C, respectively.
An expression of the form ‘a-b-c’ means that over the corresponding segment
the value a_{i,j} in y_{a_{i,j}}
changes consequently from a to b, then from b to c.
Connection of solutions y_1,y_2,y_3 on each sheet is shown on the figure
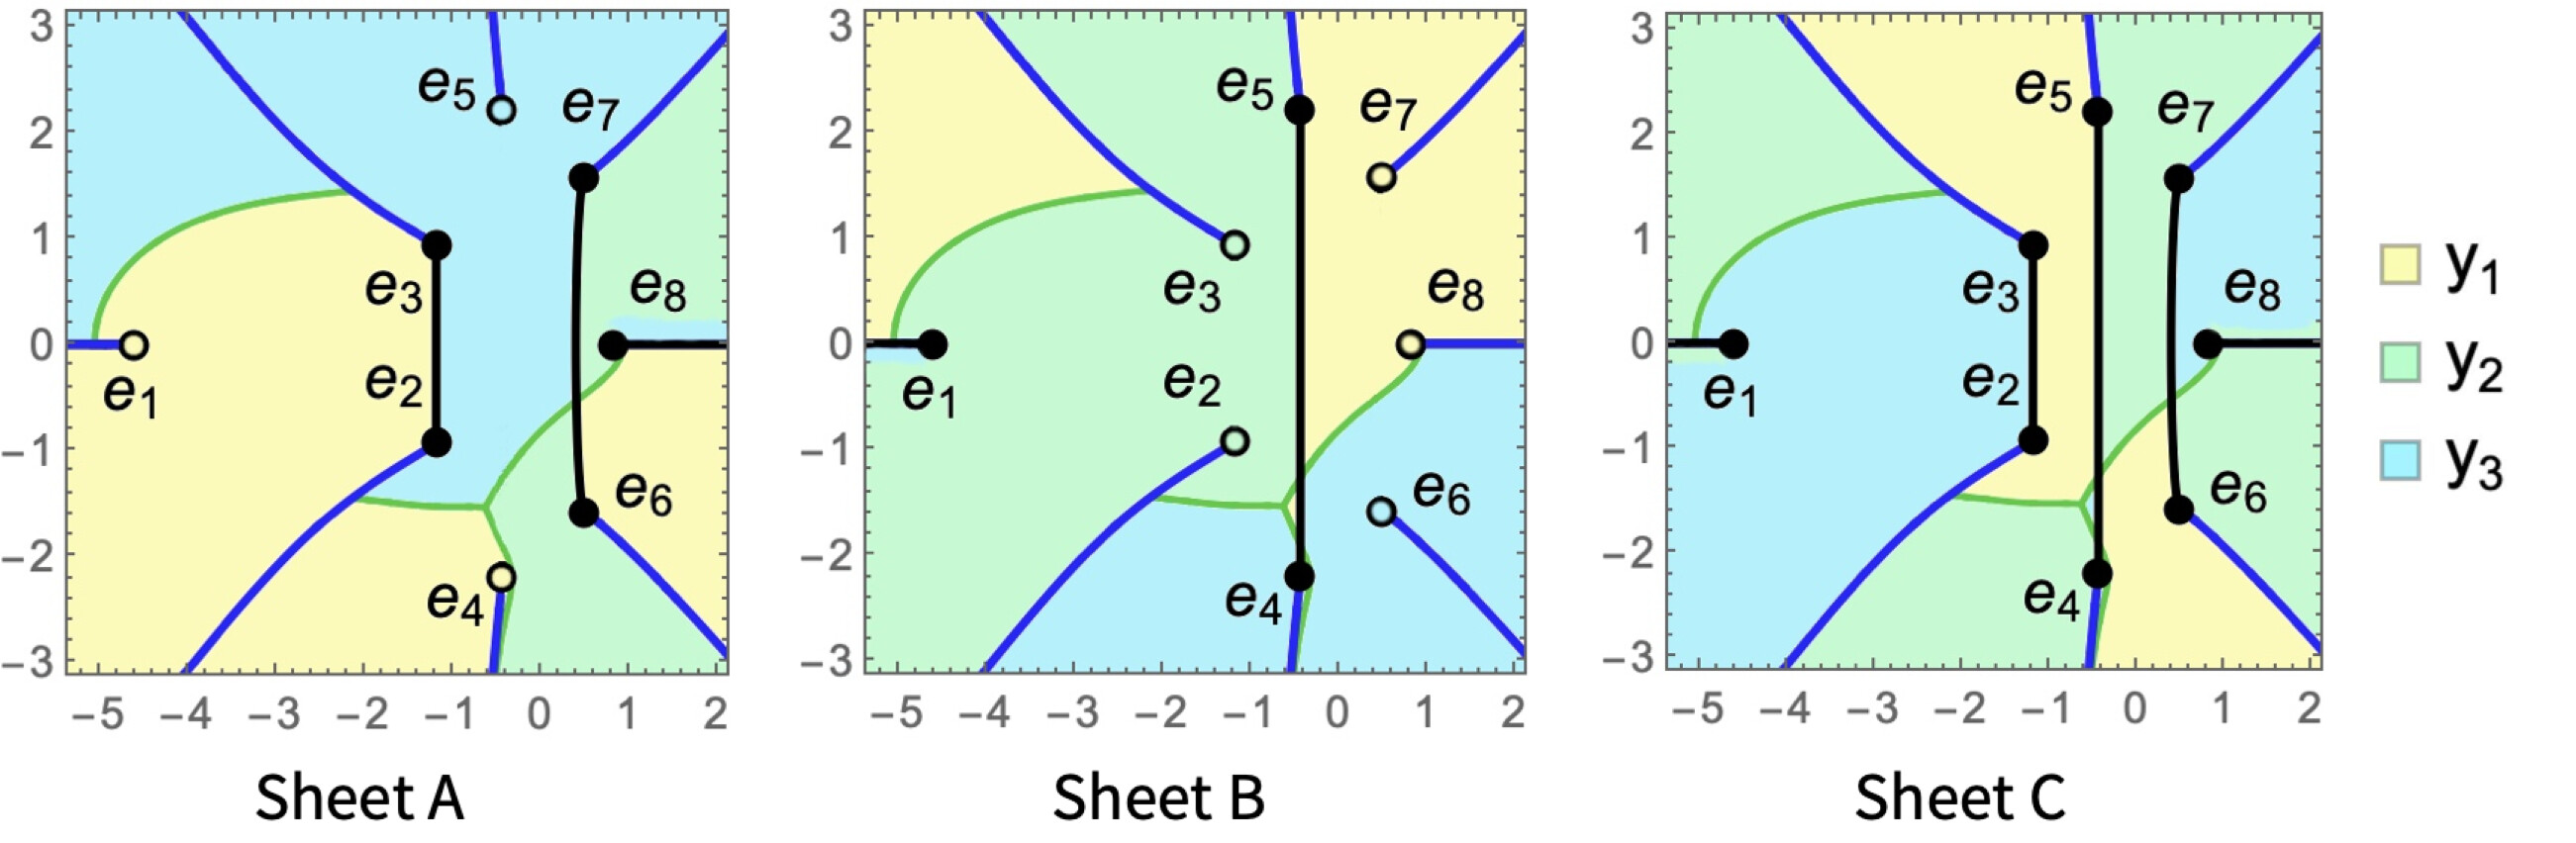
The x-plane is marked by three colors: yellow, light green, and sky blue, each shows where the areas of y_1,y_2, and y_3, correspondingly, are located. Every picture represents one sheet.
Note that all cuts can be reached on Sheet C, as well as all branch points.
Canonical homology basis
Let \mathfrak{a}-cycles encircle cuts between finite branch points counter-clockwise:
- \mathfrak{a}_1 encircles [B_2,B_3]
- \mathfrak{a}_2 encircles [B_4,B_5]
- \mathfrak{a}_3 encircles [B_6,B_7]
All \mathfrak{a}-cycles are located on Sheet C.
Let \mathfrak{b}_k-cycle emerges from the cut
[B_8,\infty)\cup (\infty,B_1] and enters the cut [B_{2k},B_{2k+1}].
Then \mathfrak{b}_1-cycle goes through Sheets C and A, \mathfrak{b}_2 through Sheets C and B, \mathfrak{b}_3 through Sheets C and A.

On the figure, \mathfrak{a}-cycles are marked in grey,
and \mathfrak{b}-cycles are marked in brown. Solid line stands for y_1, dashed for y_2, and dotted for y_3.
First and second kind differentials
A (3,4)-curve possesses the gap
sequence \{1,2,5\},
and the first kind differentials have the form
Second kind differentials associated with the first ones on the curve are defined as follows
First kind integrals
Let \mathcal{A}^{[a]}_{i,j} denote the first kind integral between branch points e_i and e_j
computed with y = y_a(x):
Integrals are computed with the help of NIntegrate.
In order to verify, that the model of Riemann surface given above is constructed correctly, we
compute first kind integrals along the path \tilde{\gamma} on all Sheets. That is
where n_{i,j}=a_{i,j}, or b_{i,j}, or c_{i,j}, depending on the sheet.
The integrand of \mathcal{A}_{i,j}^{[n_{i,j}]}
is taken with
y =y_{ n_{i,j} }(x) , and is a function of x. Note, that the path in \mathcal{A}^{[n_{0,1}]}_{0,1}
starts below the real axis, and the path in \mathcal{A}^{[n_{8,0}]}_{8,0} ends above the real axis.
This is essential for the relations presented below.
A lift of the continuous path to each sheet, closed by a semi-circle around infinity,
is homotopic to zero, an so relations hold
which serve for verification. In fact, a simpler path \gamma is used.
And relations acquire the form
At the same time, another path homotopic to zero on each sheet exists,
and so produces another set of relations:
Evidently, \mathcal{A}^{[n_{i,j}]}_{i,j} = - \mathcal{A}^{[n_{j,i}]}_{j,i}, and
\mathcal{A}^{[a_{i,j}]}_{i,j}+\mathcal{A}^{[b_{i,j}]}_{i,j}+\mathcal{A}^{[c_{i,j}]}_{i,j} = 0.
In fact, only integrals with one change of y-values are computed. The point where this change occurs on a line segment is found as a point of discontinuity of each y_a. Thus, integrals \mathcal{A}^{[n_{2,4}]}_{2,4}, \mathcal{A}^{[n_{4,6}]}_{4,6}, \mathcal{A}^{[n_{6,7}]}_{6,7}, \mathcal{A}^{[n_{6,8}]}_{6,8} are computed with two different values of y_a. For example, on Sheet A
where d denotes the point of intersection of the line segment [e_2,e_4] with the contour \Upsilon.
Reducing the number of intersections with \Upsilon, we replace \mathcal{A}^{[n_{4,5}]}_{4,5} with the sum \mathcal{A}^{[n_{4,6}]}_{4,6}+\mathcal{A}^{[n_{6,5}]}_{6,5}.
First kind periods
Periods are calculated according to the picture of homology cycles. Namely,
Here \omega_k denotes the k-th column of \mathfrak{a}-period matrix \omega,
and \omega'_k denotes the k-th column of \mathfrak{b}-period matrix \omega'.
These first kind period matrices are not normalized.
The Riemann period matrix is obtained by
and is supposed to be a symmetric matrix with positive imaginary part. The latter serves for verification.
Second kind integrals and periods
A second kind integral
\mathcal{B}^{[a]}_{i,j}
between e_i and
e_j with
y = y_a(x)
is computed by
These integrals are used in computation of second kind periods, with respect to the same homology cycles. Namely,
Here \eta_k denotes the k-th column of \mathfrak{a}-period matrix \eta,
and \eta'_k denotes the k-th column of \mathfrak{b}-period matrix \eta'.
These second kind period matrices together with first kind period matrices \omega, \omega'
satisfy the Legendre relations, see 2 for more details.
We also compute the symmetric matrix \varkappa required in the definition of \sigma-function:
Its symmetric property serves for verification.
Computation of \wp-functions
\wp-Functions are defined through \sigma-function, and the latter can
be defined as a modification of the Riemann \theta-function:
The characteristic [K] of the vector of Riemann constants is found as a half-integer characteristic
where \theta-function at u=0 has the maximal order of vanishing. This order is computed with respect to the Sato weight, which is \mathrm{wgt}\, x = n = 3, \mathrm{wgt}\, y = s = 4 on this curve.
Also \mathrm{wgt}\,\mathrm{d} u_i = -i, and \mathrm{wgt}\,\mathrm{d} r_i = i, and numbers i coincide with elements of the Weierstrass gap sequence.
It is known from [BEL1999], that on an (n,s)-curve
Let \mathfrak{d} = - \mathrm{wgt}\ \sigma, then
On the (3,4)-curve with the canonical homology basis defined above, we have
\wp-Functions can be computed in terms of \theta-function, see 2 for more details.
Example 3a
Let a divisor D be composed of 3 points:
On the figure x-coordinates of the points are marked in orange, red, and magenta,
as well as paths to them.

The points P_1 and P_3 are located on Sheet A, and P_2 on Sheet B.
A path to each point starts at -\infty - \imath \epsilon on Sheet C. Below paths to each point are described in detail.
P_1 is close to the branch point B_3 on Sheet A. The path to P_1 which we choose goes from -\infty below B_1 to B_3 on Sheet C, then enters the cut [B_2,B_3] and emerges on Sheet A, and finally reaches P_1:
P_2 is close to B_5 on Sheet B. A path to P_2 goes on Sheet C
from -\infty below B_1 and B_2 to B_4. Here the path enters the cut [B_4,B_5] and emerges on Sheet B, then goes to (e_2,y_2(e_2)) and to B_5,
rounds B_5 from the above, and
reaches P_2 on Sheet$\ $B:
P_3 is close to B_6 on Sheet A. A path to P_3 goes on Sheet C
from -\infty below B_1, B_2 and B_4 to B_6. Then the path enters the cut [B_6,B_7] and emerges on Sheet A, where it reaches P_3:
Here we use first kind integrals computed before. Integrals to points are computed with the help of NIntegrate.
Then the Abel image of D is obtained by
The divisor D is uniquely represented by the values of six \wp-functions at
u = \mathcal{A}(D):
which serve as coefficients of the two polynomial functions \mathcal{R}_6 and
\mathcal{R}_7 defining a solution of the Jacobi inversion problem.
On the other hand, these two functions are computed from coordinates of the points of D:
The coefficients of \mathcal{R}_6 and
\mathcal{R}_7 obtained in these two ways
coincide with an accuracy of 10^{-11}. This proves that the Abel images of the points are computed correctly.
Example 3b
Now we slightly modify the divisor D by choosing different y-coordinates:

The points P_1 and P_3 are located on Sheet B, and P_2 on Sheet A.
A path to every point starts at -\infty - \imath \epsilon on Sheet C.
A path to P_1 goes above B_1 and B_3 to B_5 on Sheet C, then enters
the cut [B_4,B_5], emerges on Sheet B, goes to the point
(e_3, y_2(e_3)),
and reaches P_1:
A path to P_2 goes above B_1 B_3 and B_5 to B_7 on Sheet C, then enters
the cut [B_6,B_7], emerges on Sheet A, goes to
(e_5, y_3(e_5)),
and reaches P_2:
A path to P_3 goes below B_1 and B_2 to B_4 on Sheet C,
enters the cut [B_4,B_5], emerges on Sheet B, goes to
(e_6, y_3 ( e_6 ))
and reaches P_3:
Then we compute the six \wp-functions, which serve as coefficients of
\mathcal{R}_6 and
\mathcal{R}_7 and define the given divisor D uniquely.
By computing the functions \mathcal{R}_6 and
\mathcal{R}_7 from coordinates
of the points of D we verify that the Abel images are found correctly.
References
[BEL1999] Buchstaber V. M., Enolskii V. Z., Leykin D. V., Rational analogs of abelian functions,
Functional Analysis and Its Applications, 33:2 (1999) pp.83-94
AMap-C34-Exmpl3-Publ.nb (6.62 MB)
 – you have earned Featured Contributor Badge
